Page Not Found
Page not found. Your pixels are in another canvas.
A list of all the posts and pages found on the site. For you robots out there is an XML version available for digesting as well.
Page not found. Your pixels are in another canvas.
About me
This is a page not in th emain menu
Published:
This post will show up by default. To disable scheduling of future posts, edit config.yml and set future: false.
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool.
A* Search in Python for wheeled mobile robot path planning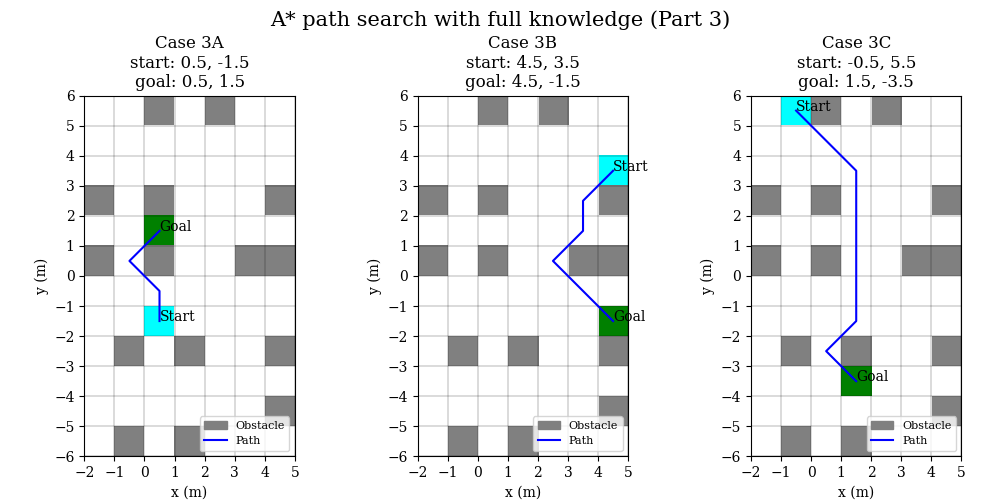
Virtual tasks for eye gaze characterization, and open-source ROS wrapper for Tobii Pro Glasses 3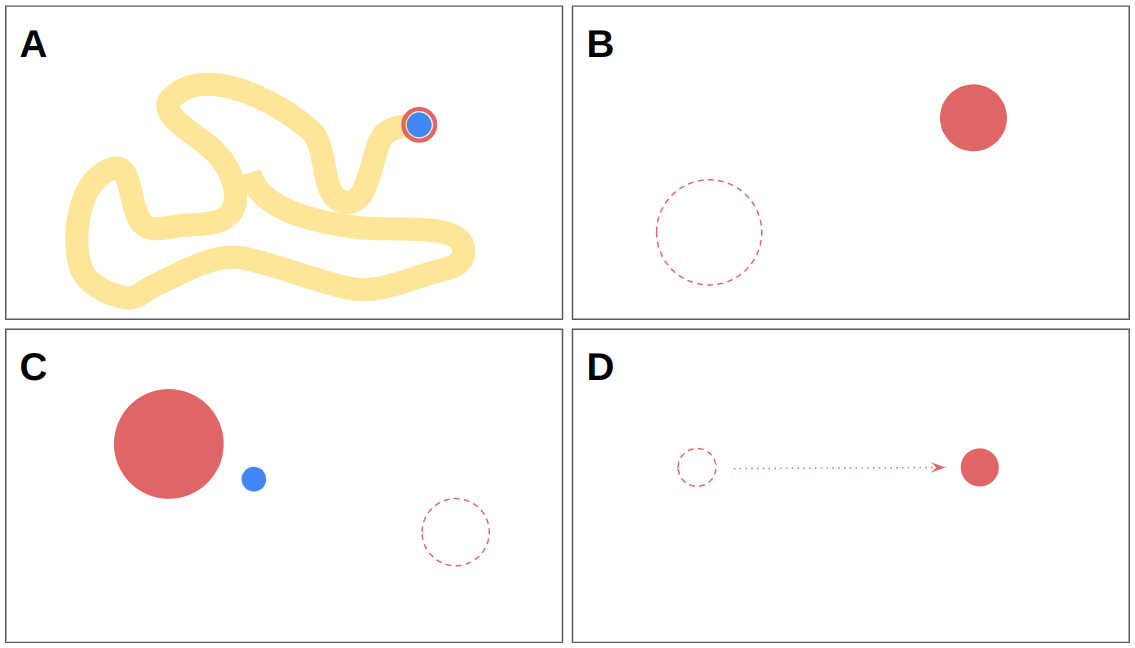
Gaussian Mixture Regression (GMM-GMR) in Python to learn an inverse kinematics model of a robot based on a given dataset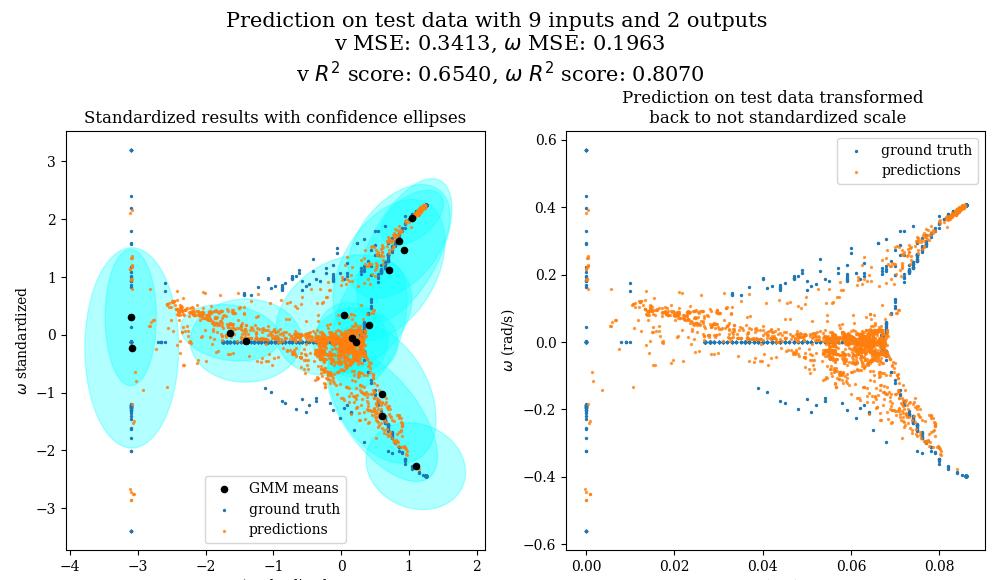
ROS implementation of SLAM using an extended kalman filter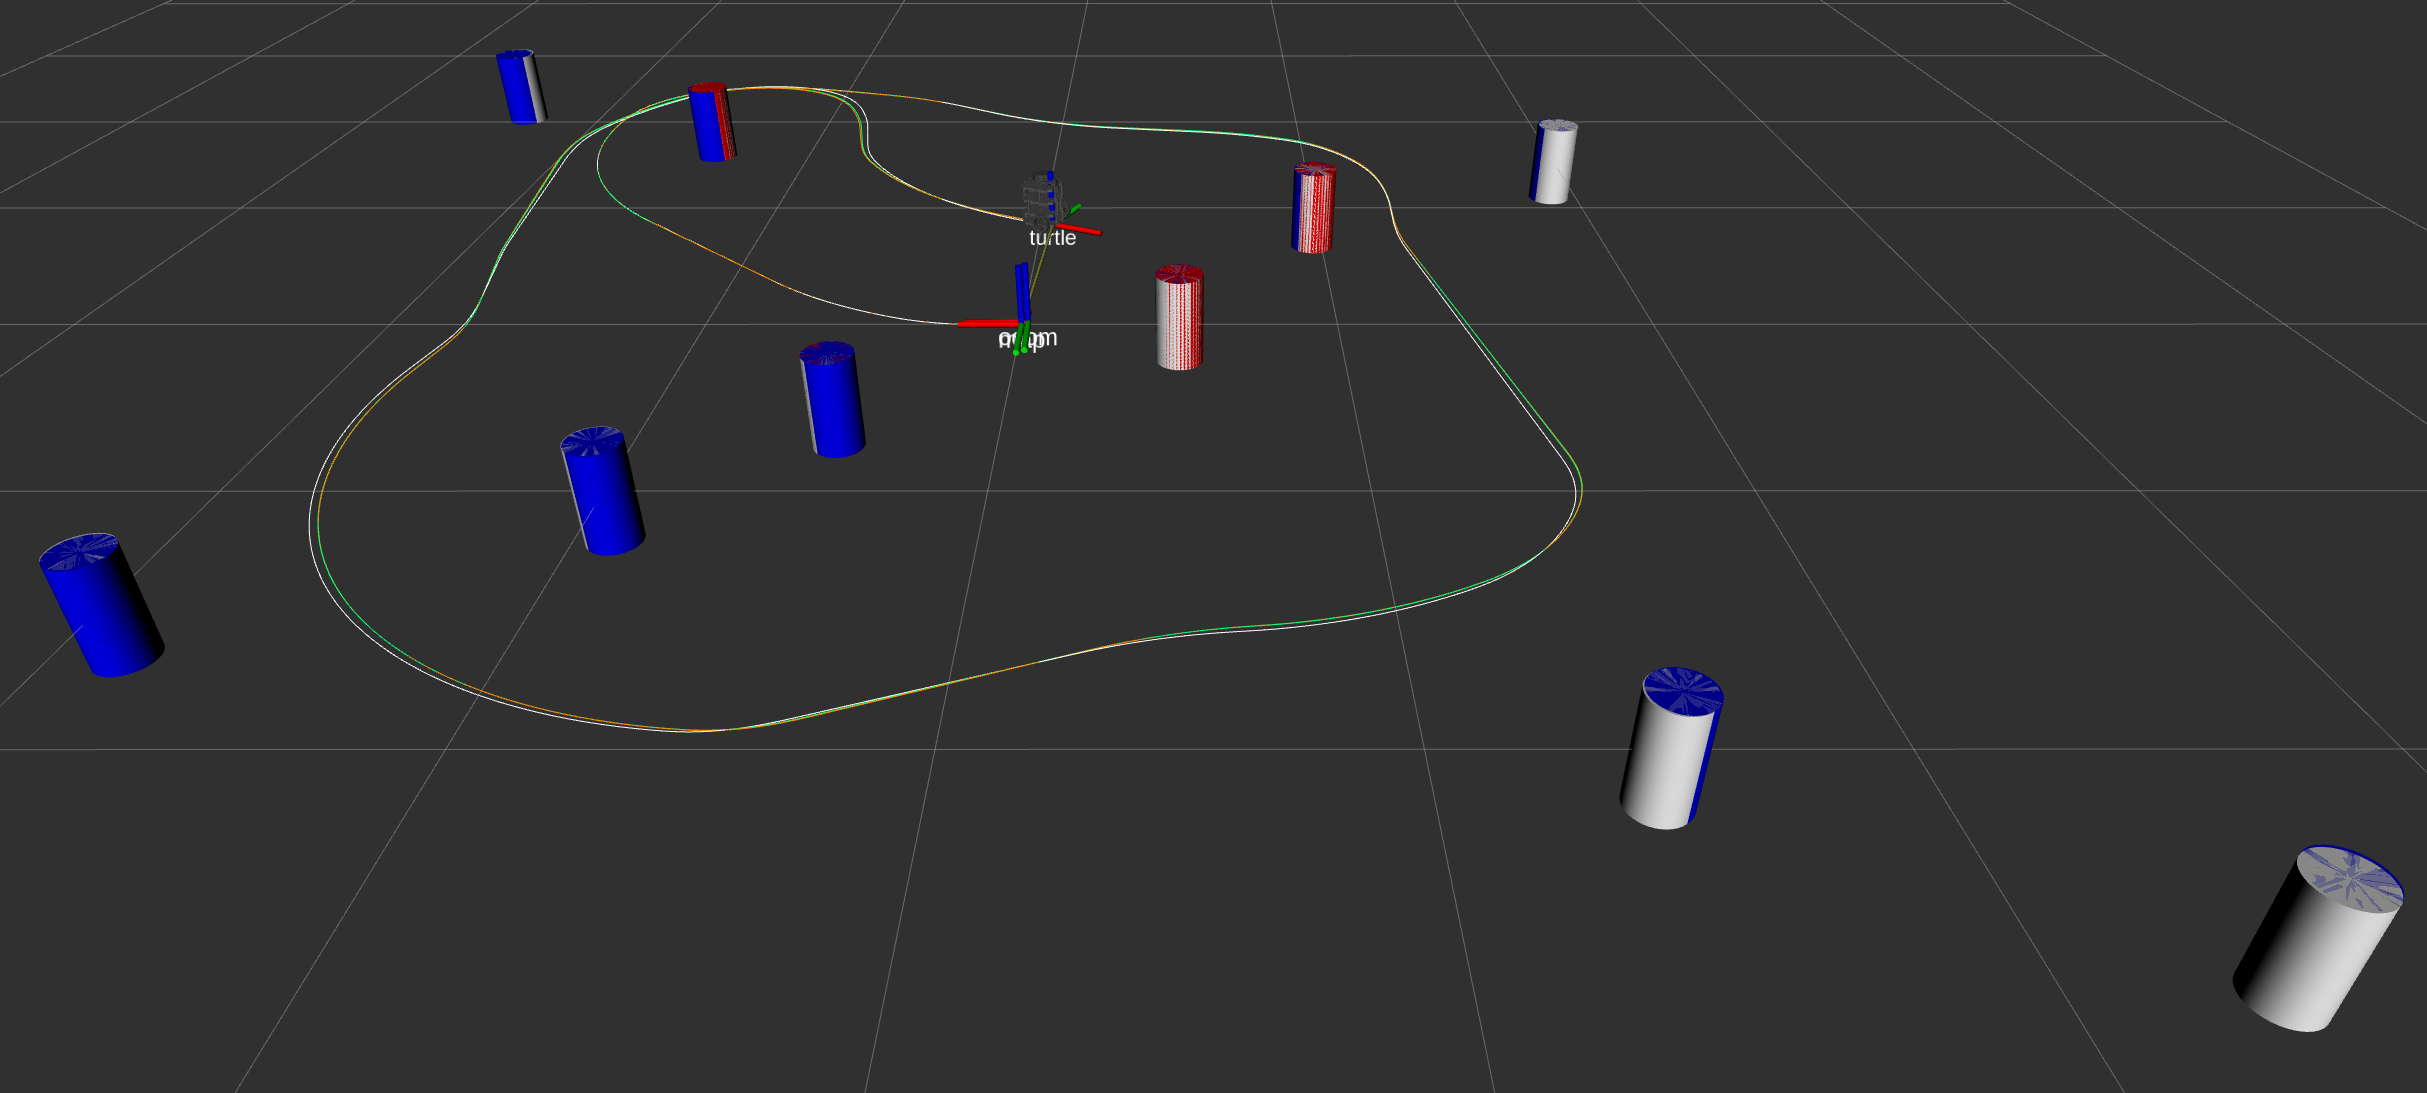
Implementation of SQP in Python (from scratch)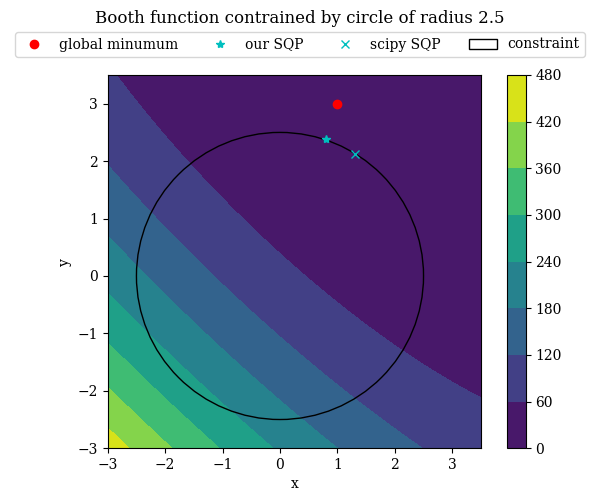
User-customized, task-agnostic assistance for high-DoF robot arm teleoperation via a low-dimensional Sip/Puff interface
Unscented Kalman Filter for localization of a wheeled mobile robot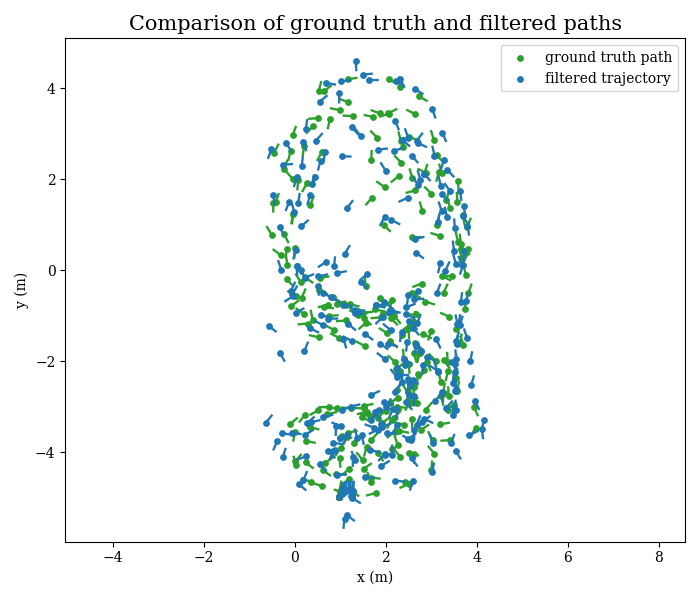
Reactive shared-control scheme for safe powered wheelchair driving, validated in a large-scale longitudinal user study
Published in International Conference on Rehabilitation Robotics 2022, Rotterdam, 2022
Creating a custom interface to assistive device control mapping based on the design of a user’s bias profile
Recommended citation: Thompson, A.*, Loke, L. YC.*, & Argall, B. (2022, July). Control interface remapping for bias-aware assistive teleoperation. In 2022 International Conference on Rehabilitation Robotics (ICORR) (pp. 1-6). IEEE.
Published in International Conference on Rehabilitation Robotics 2023, Singapore, 2023
Open source data gathering and assessment tasks for individualized characterization of eye gaze interface use.
Recommended citation: Loke, L. YC., Barsoum, D. R., Murphey, T. D., & Argall, B. D. (2023, September). Characterizing eye gaze for assistive device control. In 2023 International Conference on Rehabilitation Robotics (ICORR) (pp. 1-6). IEEE.
Published in International Symposium on Experimental Robotics (ISER) 2023, 2023
User-customized, task-agnostic assistance for high-DoF robot arm teleoperation, evaluated in a preliminary case study with 3 SCI participants.
Recommended citation: Nejati Javaremi, M., Loke, L. Y.C., & Argall, B. D. (2023). Interface-Aware Assistance for 7-DoF Robot Arm Teleoperation: Case Studies on Feasibility. In Proceedings of the International Symposium on Experimental Robotics (ISER). https://www.argallab.northwestern.edu/files/2024/03/23iser_nejati-51fde4021668d9e2.pdf
Published in The International Journal of Robotics Research (IJRR), Special Issue: ISER 2023, 2025
Task-agnostic, interface-aware handling of unintended interface operation during assisted robot arm teleoperation, evaluated with participants with spinal cord injury.
Recommended citation: Nejati Javaremi, M., Loke, L. Y.C., & Argall, B. D. (2025). Task-agnostic and interface-aware handling of unintended interface operation for robot arm teleoperation: Insights and case study evaluations by persons with spinal cord injury. The International Journal of Robotics Research (IJRR) Special Issue: ISER 2023. https://www.argallab.northwestern.edu/files/2026/08/25ijrr_nejati_javaremi.pdf
Published in Wearable Technologies, Volume 6, Cambridge University Press, 2025
Open source data gathering and assessment tasks for individualized characterization of eye gaze interface use, and eyegaze for mental workload assessment.
Recommended citation: Loke, L. YC., Barsoum, D. R., Murphey, T. D., & Argall, B. D. (2025). Characterizing eye gaze and mental workload for assistive device control. Wearable Technologies, 6, e13.
Published in Robotics: Science and Systems (RSS) 2025, 2025
A reformulated, task- and environment-agnostic algorithm for user-customized robot teleoperation assistance, evaluated with 8 SCI participants.
Recommended citation: Loke, L. Y.C., & Argall, B. D. (2025). Interface-Level Intent Inference for Environment-Agnostic Robot Teleoperation Assistance. In Proceedings of the Robotics: Science and Systems (RSS) conference. https://www.argallab.northwestern.edu/files/2025/05/25rss_loke.pdf
Published in International Conference on Rehabilitation Robotics (ICORR) 2025, 2025
Curating interface maps for robot teleoperation.
Recommended citation: Barsoum, D. R., Zhang, M. H., Loke, L. Y.C., & Argall, B. (2025). Curating Interface Maps for Robot Teleoperation. In Proceedings of the International Conference on Rehabilitation Robotics (ICORR). https://www.argallab.northwestern.edu/files/2025/05/25icorr_barsoum.pdf
Published in ACM/IEEE International Conference on Human-Robot Interaction (HRI) 2026, 2026
Interface-aware trajectory reconstruction for robot learning from teleoperated demonstration.
Recommended citation: Barsoum, D. R., Nejati Javaremi, M., Loke, L. Y.C., & Argall, B. (2026). Interface-Aware Trajectory Reconstruction for Robot Learning. In Proceedings of the ACM/IEEE International Conference on Human-Robot Interaction (HRI). https://www.argallab.northwestern.edu/files/2026/08/26hri_barsoum.pdf
Published in Robotics: Science and Systems (RSS) 2026, 2026
A reactive shared-control scheme for local guidance around obstacles during powered wheelchair driving, validated in a large-scale longitudinal user study across a range of motor impairments and control interfaces.
Recommended citation: Loke, L. Y.C., Goh, J. X., Puckett, K. S. P., Zhang, M. H., Zaino, N. L., & Argall, B. D. (2026). A Minimal, Deterministic Approach to Shared Control for Safe Powered Wheelchair Driving. In Proceedings of the Robotics: Science and Systems (RSS) conference. https://www.argallab.northwestern.edu/files/2026/08/26rss_loke.pdf
Published:
This is a description of your talk, which is a markdown files that can be all markdown-ified like any other post. Yay markdown!
Published:
This is a description of your conference proceedings talk, note the different field in type. You can put anything in this field.
Undergraduate course, University 1, Department, 2014
This is a description of a teaching experience. You can use markdown like any other post.
Workshop, University 1, Department, 2015
This is a description of a teaching experience. You can use markdown like any other post.